OOMWOO PCBs: what, how and why
A module-by-module tour of the main board: compute, real-time control, power and the fail-safe design.
Read the write-up →
Raspberry Pi, ROS2 and 2D LiDAR. It maps your home and cleans on its own — fully local, no cloud, no lock-in. The firmware is open, so you can audit it and nothing leaves your home. 3D-printable and hackable.
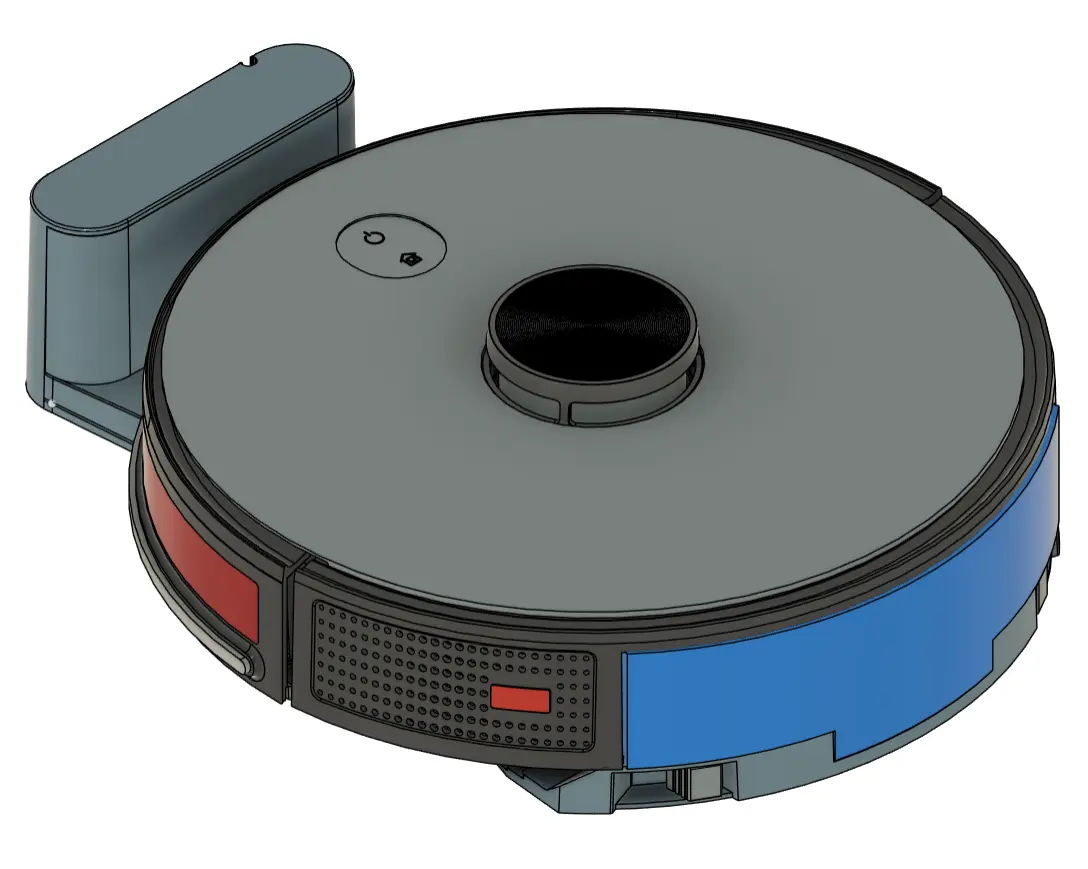 Reference design — roughly how it'll look
Short, unpolished clips straight from the simulator and the workbench.
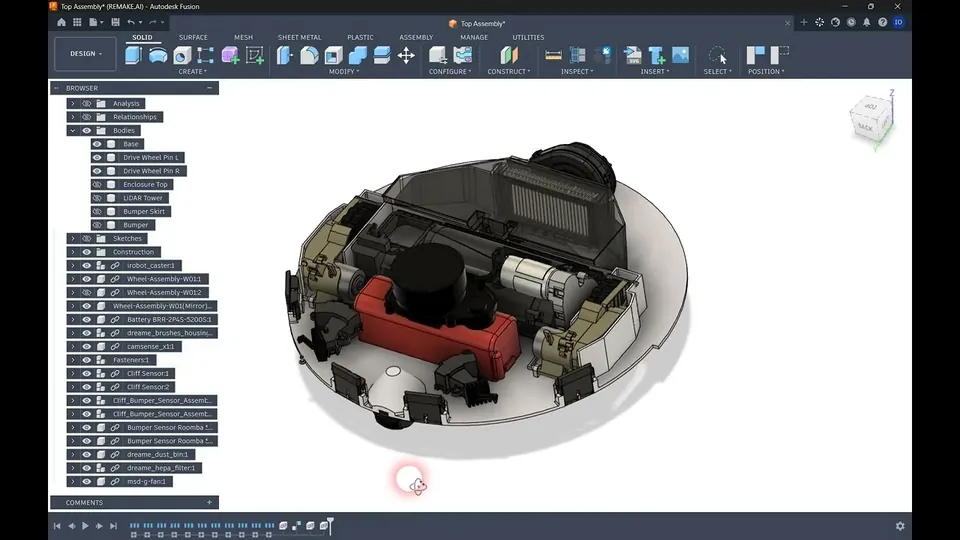
Base, enclosure and bumper each have a flat side to print on, built around off-the-shelf wheels, battery, fan and sensors.
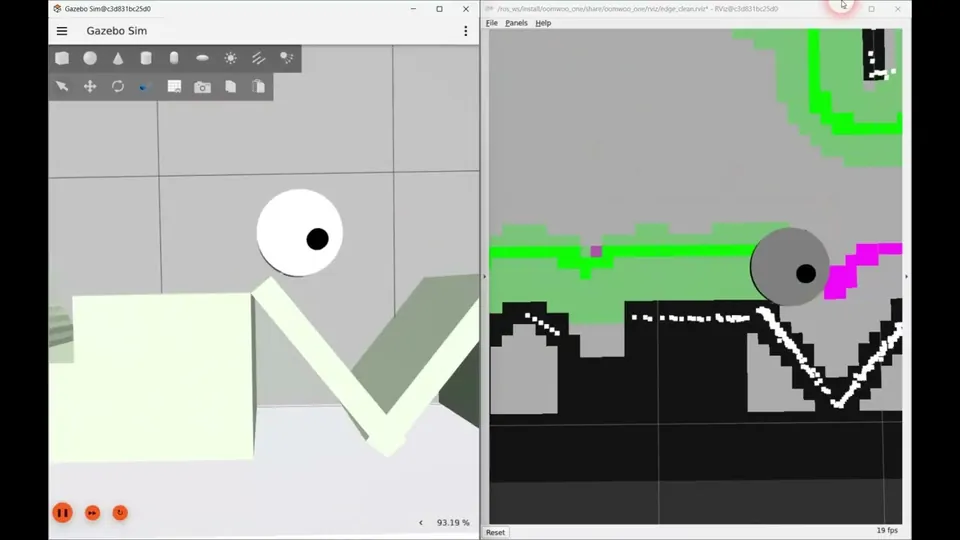
Sweeps along every wall and obstacle once, and keeps track of what is already clean.
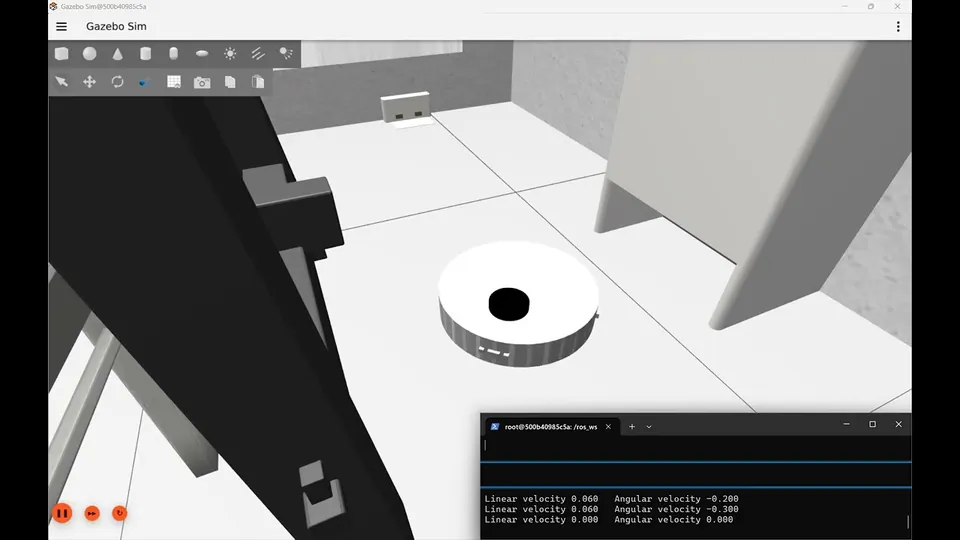
Finds the dock by its beacon, then lines up on it with the LiDAR.
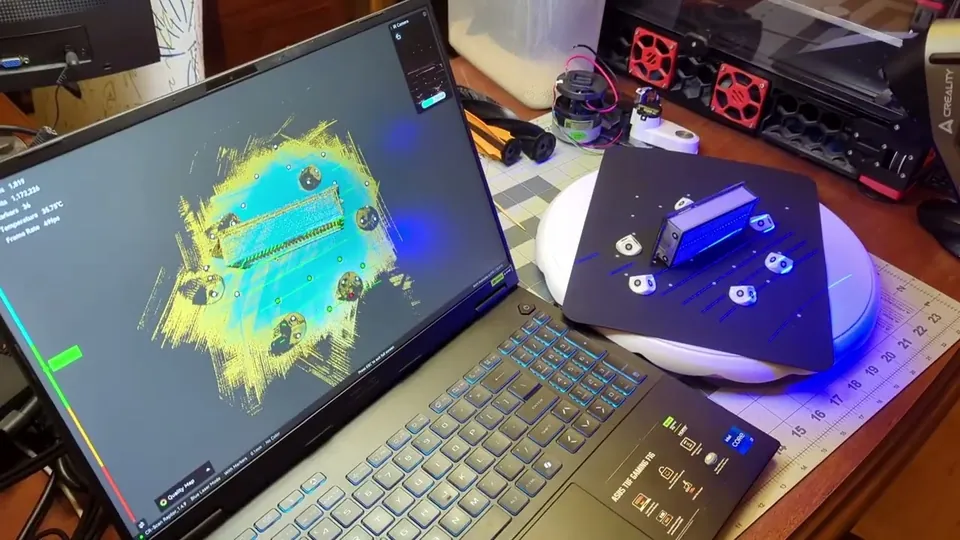
Every part we buy is 3D scanned, so the chassis can be designed around it.
Built in the open, so here is the honest state of it.
Drive it in Gazebo today - SLAM, navigation, teleop. No hardware needed.
Schematic in review, parts placed. The board outline waits on the mechanical design.
Cleans along every wall and obstacle edge, and docks - in simulation. Whole-floor coverage is next.
Printable base, enclosure and bumper designed, around metal-gearbox motors and simple printed gears. Mechanisms in progress.
Serial protocol between compute and motor board merged and tested.
Updated 5 Oct 2026 · task-by-task detail on the RFC board →
Long-form write-ups of what we're building, how, and why - including what didn't work.
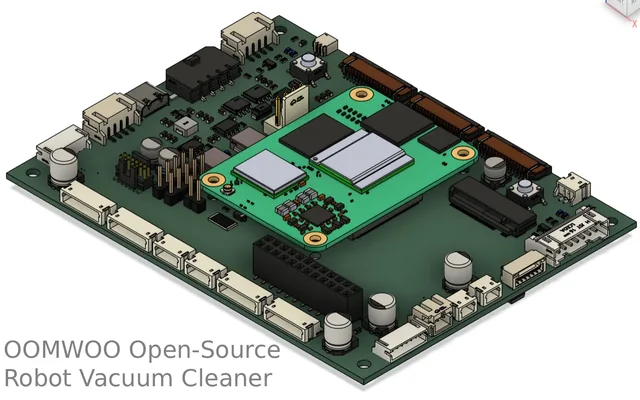
A module-by-module tour of the main board: compute, real-time control, power and the fail-safe design.
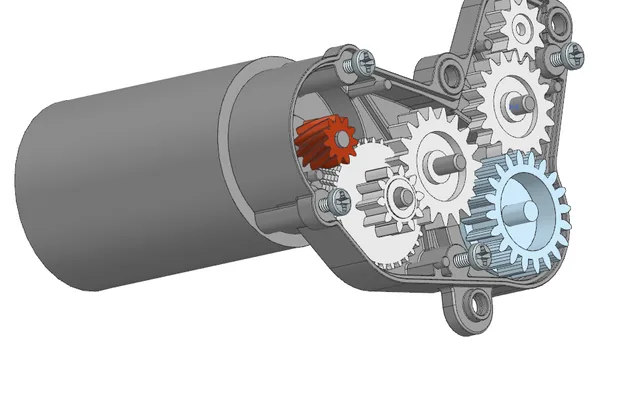
Sourcing, 3D scanning and CAD - and why the Roborock-style mops were dropped.
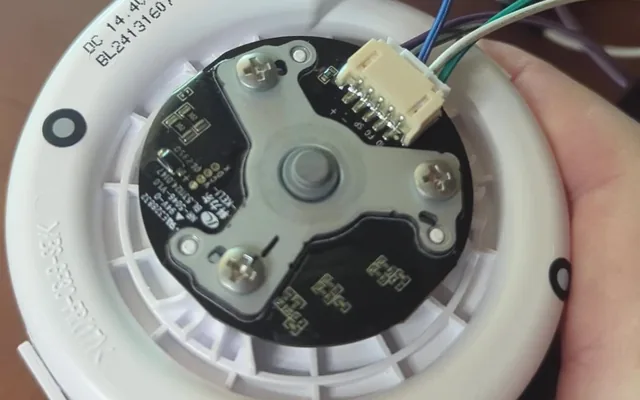
Motors, fans and brushes powered up one by one: pinouts, connectors and measured currents.
Wall following, edge cleaning, docking and localization - the problems we hit and how we solved them.
Print chassis, install software — or just follow along while it comes together.
Goals, architecture, design research and the whole open build in one place.
The dev environment is ready — install it and drive oomwoo-one in Gazebo (SLAM, Nav2, teleop), no hardware needed.
No hardware to wait for — connect an off-the-shelf Proscenic M6 Pro to ROS2 as a placeholder robot and run the same stack on real hardware.
Follow tutorial →Not a sealed appliance — an open platform you assemble, understand, and modify.
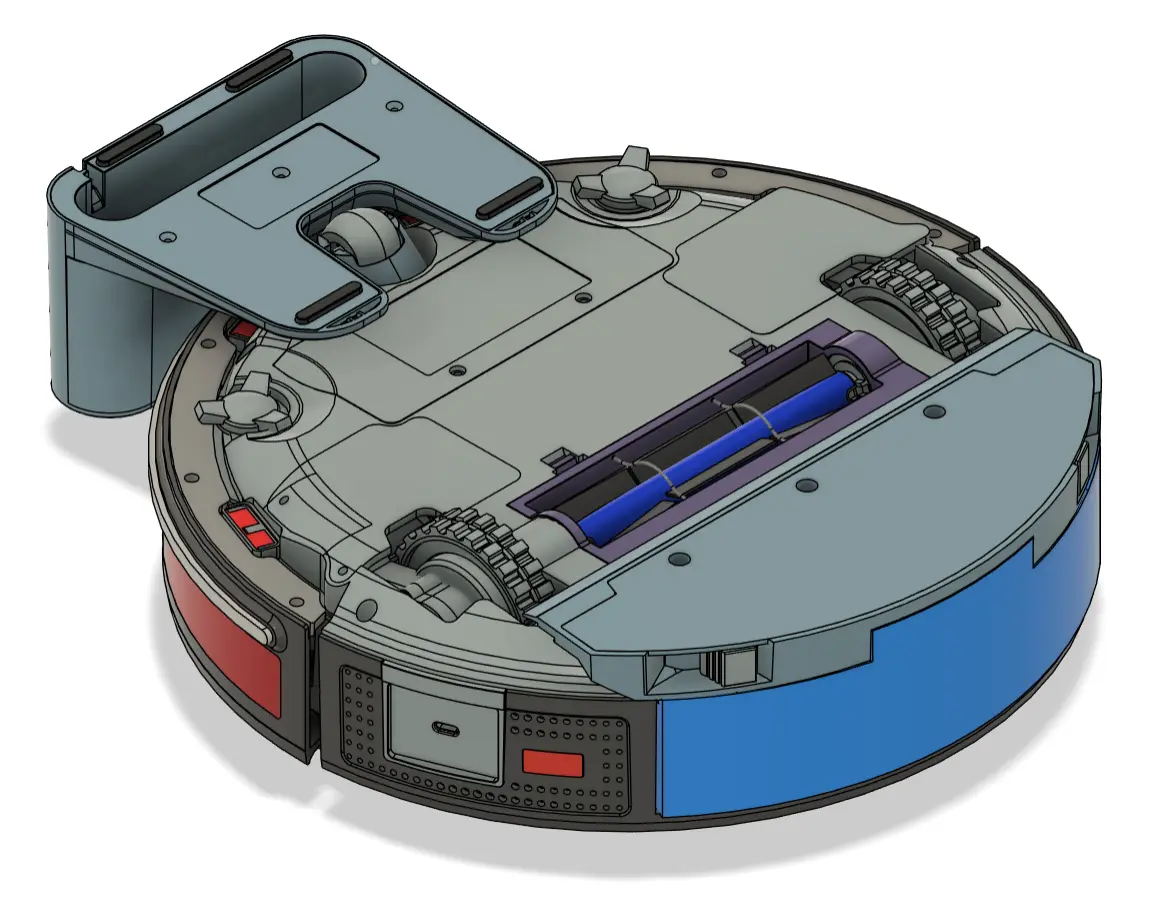
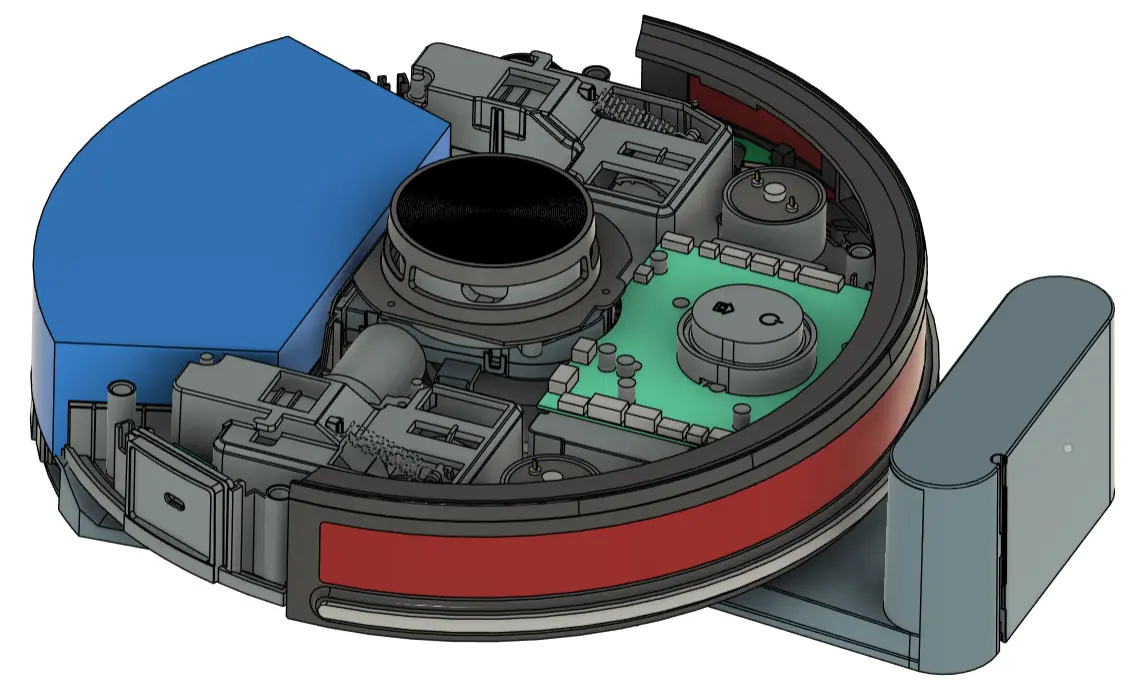
The robot is split into independent modules (RFCs). Pick one, work when you want, open a PR.
Grab a module — sim, mapping, navigation, docking, floor care and more.
How the parallel, module-based workflow works and how to submit your PR.
Ask questions, claim a module, and build in public with the rest of us.
The ones we get asked most.
Not yet. You can run it in simulation today, but the chassis and electronics are still being designed - see where the build is. Subscribe below to hear first when kits are available.
Either will work. A kit will be optional: the CAD, schematics, firmware, software and bill of materials all stay open, so you can buy the parts and print it yourself.
Yes. The dev environment runs in Docker - drive OOMWOO in Gazebo with mapping and navigation, no robot needed. Or run the same software on an off-the-shelf Proscenic M6 Pro.
That’s the plan: the phone becomes the robot’s touchscreen and its brain. The phone software doesn’t exist yet, so this spec is provisional:
Ubuntu with ROS 2 has already run on a Pixel 6 Pro. Newer Android versions restrict background apps, so expect a setup step or two. A Raspberry Pi CM4/CM5 stays the main option.
No. It maps and cleans locally, and nothing leaves your home. Home Assistant integration is there if you want it.
Pick a task from the Requests for Contributions board, read the contributing guide and say hi on Discord. Code, CAD, electronics and testing are all welcome.
Thank you for asking! Money is not an issue, so I'm not looking for donations. The best help is spreading the word - tell a friend who would want one, share OOMWOO online, or star the repo. You can also subscribe below to hear when kits are available, or pick up a task on the RFC board.
Code is Apache-2.0. Hardware design files will use an open hardware license, still to be chosen.