How I 3D print gears in POM (Delrin)
The gear plastic of consumer robot vacuums, printed reliably on a Prusa: two PETG layers first, then POM.
Read the write-up →
Raspberry Pi, ROS2 and 2D LiDAR. It maps your home and cleans on its own — fully local, no cloud, no lock-in. The firmware is open, so you can audit it and nothing leaves your home. 3D-printable and hackable.
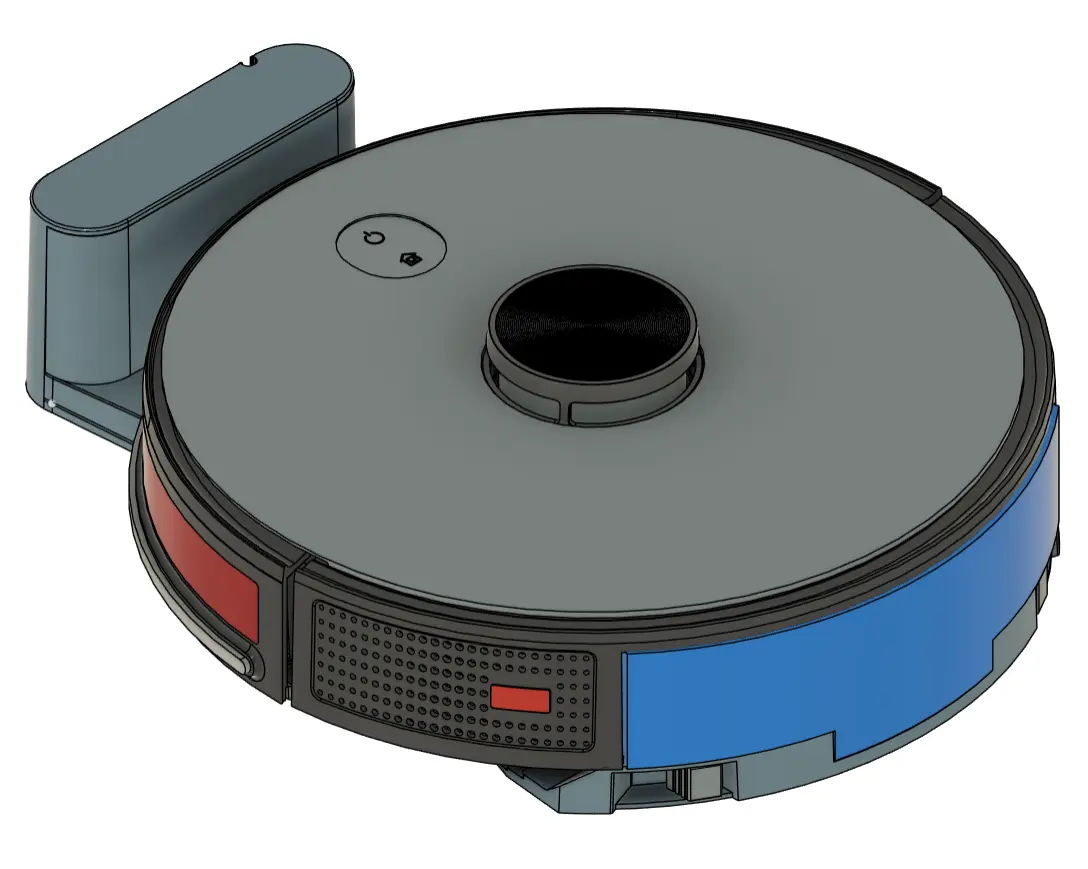 Reference design — roughly how it'll look
Short, unpolished clips straight from the workbench and the simulator.
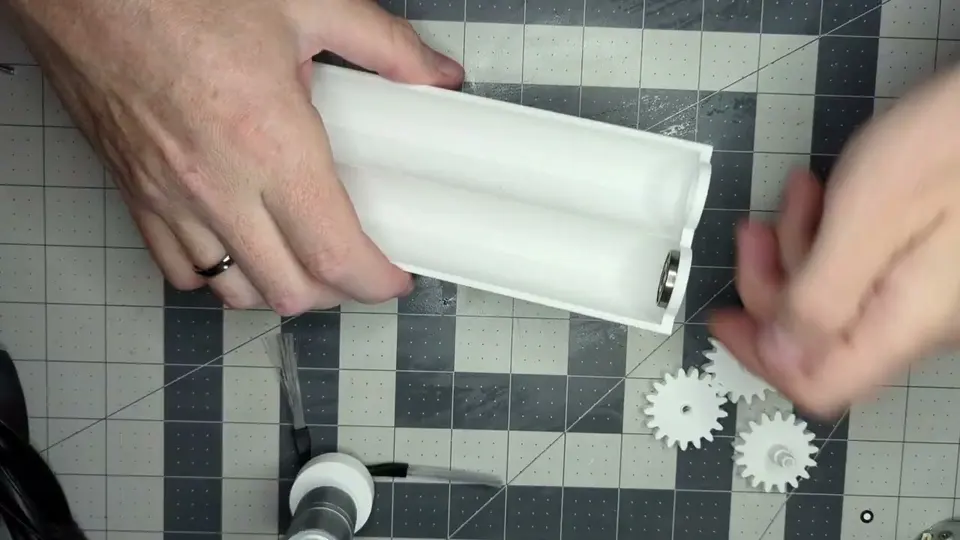
Two tapered brushes, each on a bearing and a spur gear, driven by one DC motor.
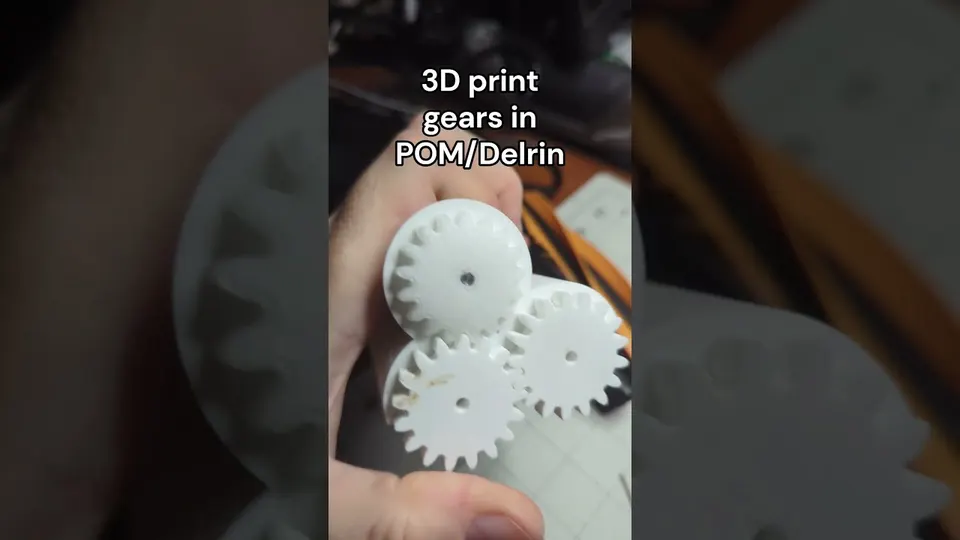
The gear plastic of consumer robot vacuums, printed on a Prusa on two layers of PETG.
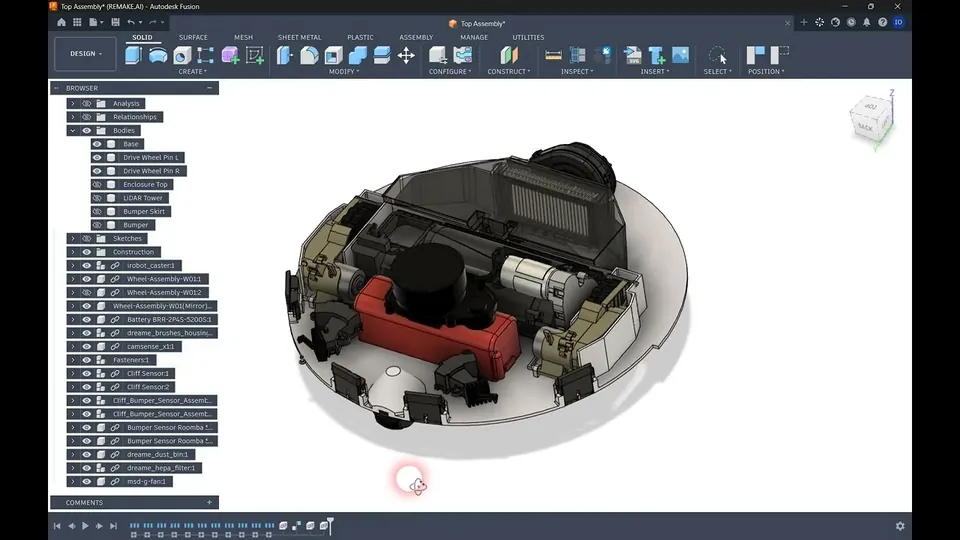
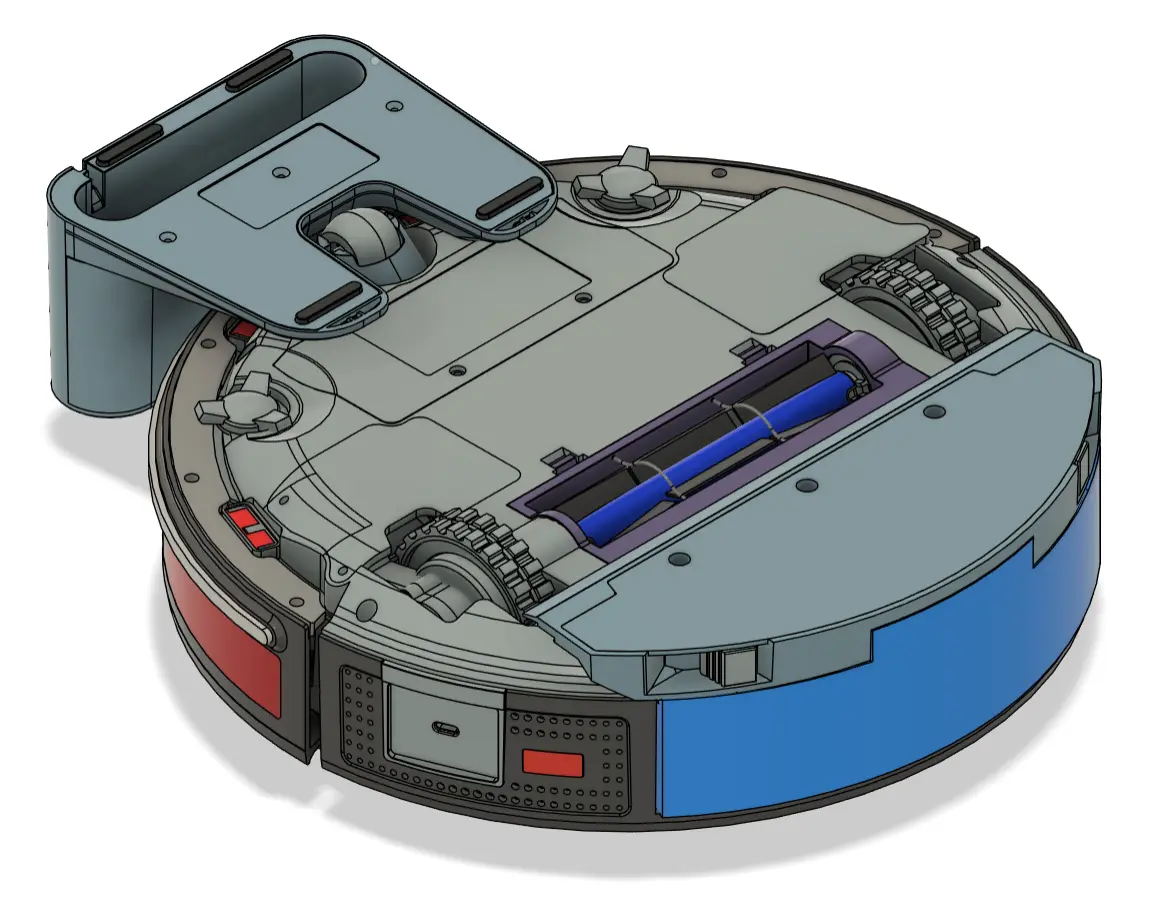
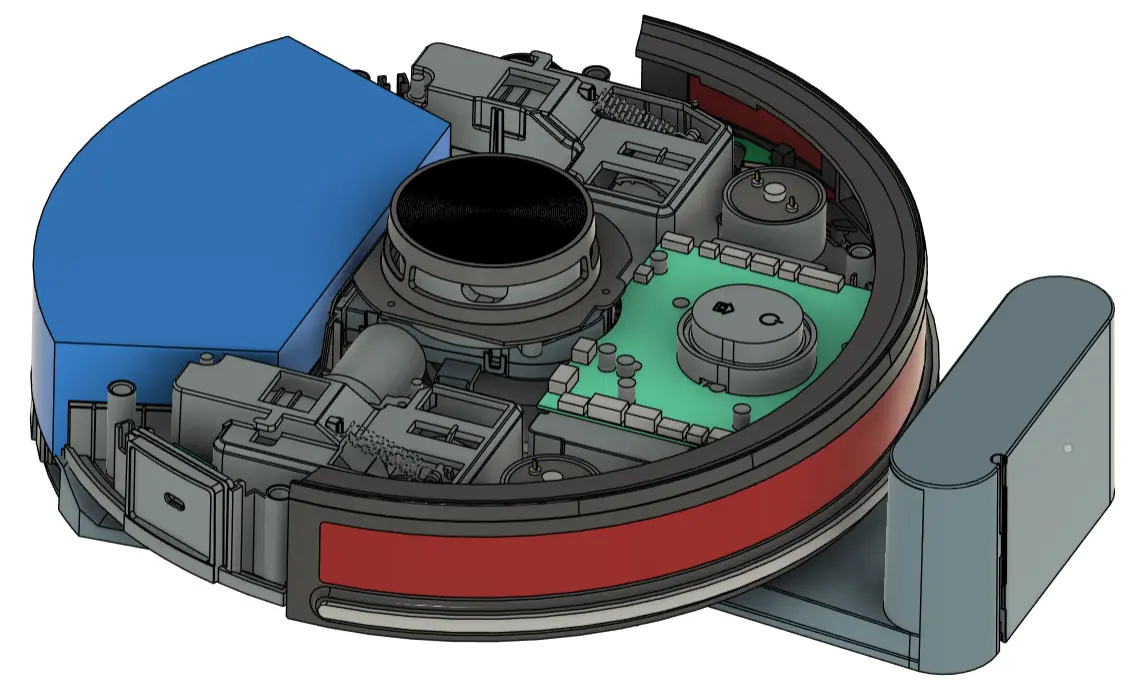
Base, enclosure and bumper each have a flat side to print on, built around off-the-shelf wheels, battery, fan and sensors.
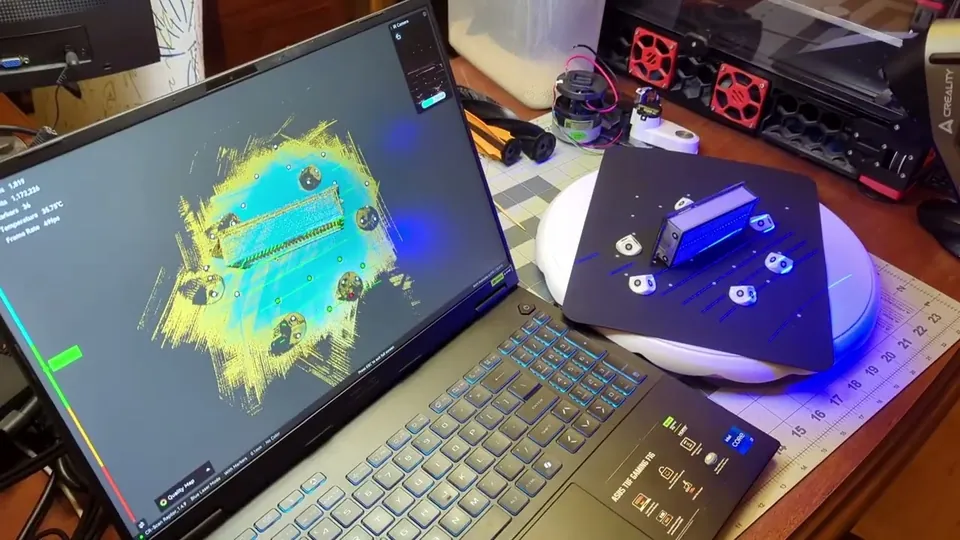
Every part we buy is 3D scanned, so the chassis can be designed around it.
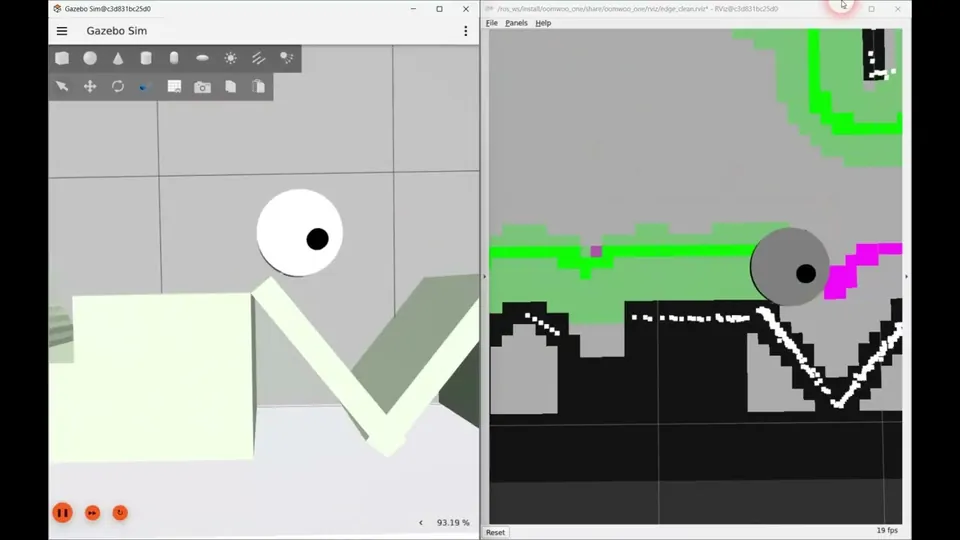
Sweeps along every wall and obstacle once, and keeps track of what is already clean.
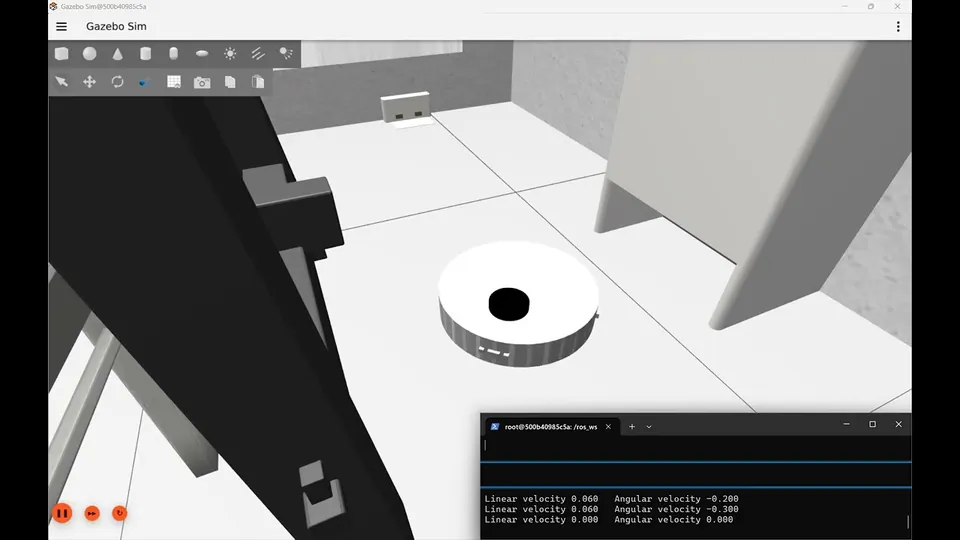
Finds the dock by its beacon, then lines up on it with the LiDAR.
Built in the open, so here is the honest state of it.
Drive it in Gazebo today - SLAM, navigation, teleop. No hardware needed.
Schematic in review, parts placed. The board outline waits on the mechanical design.
Cleans along every wall and obstacle edge, and docks - in simulation. Whole-floor coverage is next.
Printable base, enclosure and bumper designed, around metal-gearbox motors and simple printed gears. Mechanisms in progress.
Serial protocol between compute and motor board merged and tested.
Updated 5 Oct 2026 · task-by-task detail on the RFC board →
Long-form write-ups of what we're building, how, and why - including what didn't work.
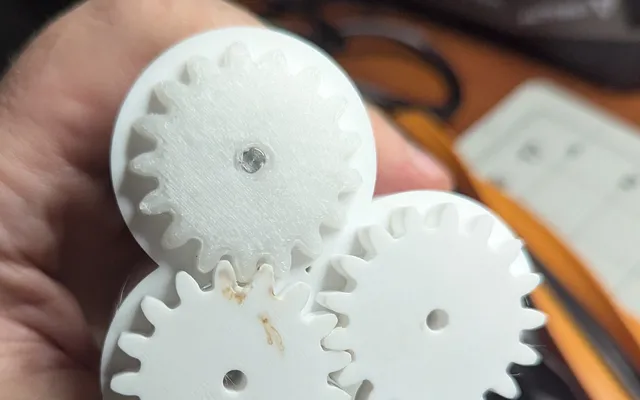
The gear plastic of consumer robot vacuums, printed reliably on a Prusa: two PETG layers first, then POM.
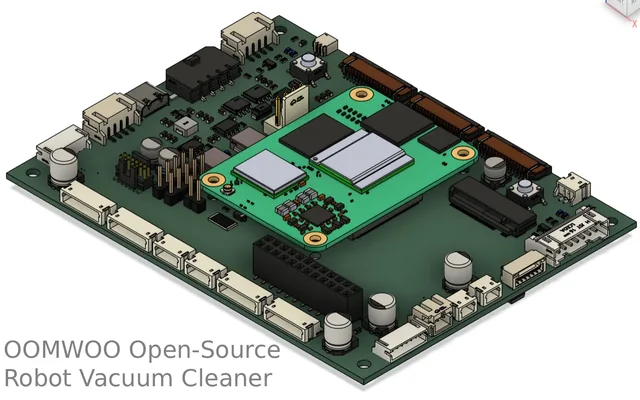
A module-by-module tour of the main board: compute, real-time control, power and the fail-safe design.
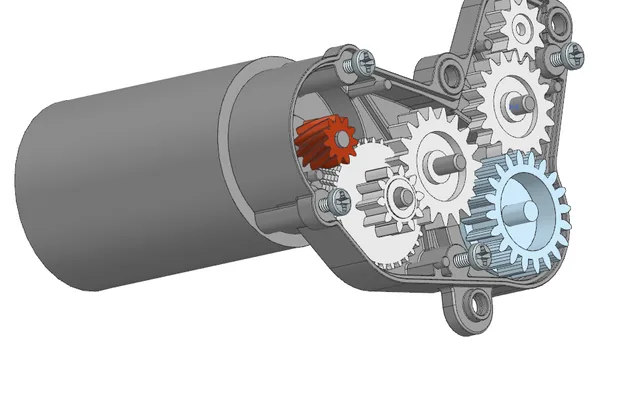
Sourcing, 3D scanning and CAD - and why the Roborock-style mops were dropped.
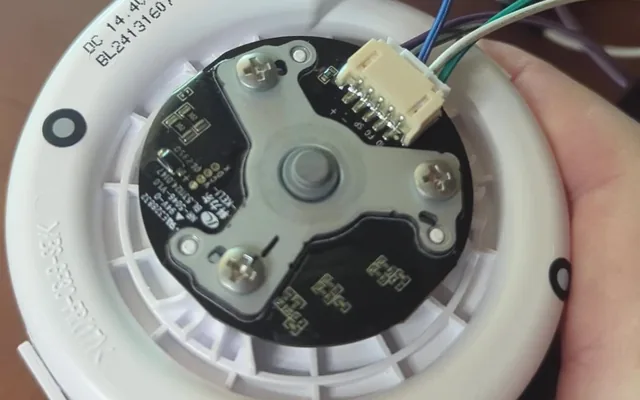
Motors, fans and brushes powered up one by one: pinouts, connectors and measured currents.
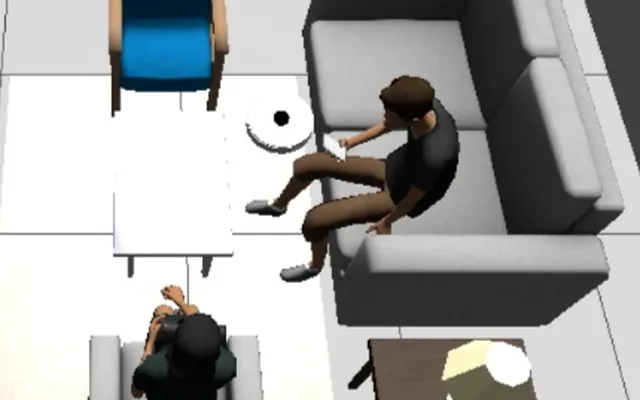
Wall following, edge cleaning, docking and localization - the problems we hit and how we solved them.
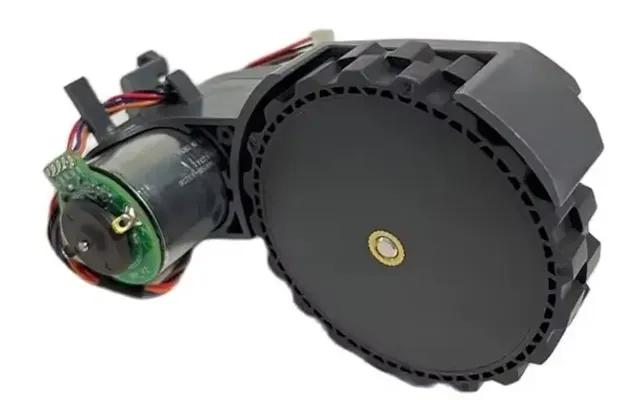
Which parts to buy and which to print, where to find them and what they cost - wheels, fans, filters and more.
Print chassis, install software — or just follow along while it comes together.
Goals, architecture, design research and the whole open build in one place.
The dev environment is ready — install it and drive oomwoo-one in Gazebo (SLAM, Nav2, teleop), no hardware needed.
No hardware to wait for — connect an off-the-shelf Proscenic M6 Pro to ROS2 as a placeholder robot and run the same stack on real hardware.
Follow tutorial →Not a sealed appliance — an open platform you assemble, understand, and modify.
The robot is split into independent modules (RFCs). Pick one, work when you want, open a PR.
Grab a module — sim, mapping, navigation, docking, floor care and more.
How the parallel, module-based workflow works and how to submit your PR.
Build updates, questions and show-and-tell. The busiest place to talk OOMWOO.
Real-time chat: ask questions, claim a module, build in public with the rest of us.
The ones we get asked most.
Not yet. You can run it in simulation today, but the chassis and electronics are still being designed - see where the build is. Subscribe below to hear first when kits are available.
On r/oomwoo - that’s where build updates are posted and most of the conversation happens. Videos go to the OOMWOO Build Log playlist on YouTube, and the long write-ups are under Built in public. For real-time chat there’s Discord, and you can subscribe for the occasional email.
Either will work. A kit will be optional: the CAD, schematics, firmware, software and bill of materials all stay open, so you can buy the parts and print it yourself.
Yes. The dev environment runs in Docker - drive OOMWOO in Gazebo with mapping and navigation, no robot needed. Or run the same software on an off-the-shelf Proscenic M6 Pro.
That’s the plan: the phone becomes the robot’s touchscreen and its brain. The phone software doesn’t exist yet, so this spec is provisional:
Ubuntu with ROS 2 has already run on a Pixel 6 Pro. Newer Android versions restrict background apps, so expect a setup step or two. A Raspberry Pi CM4/CM5 stays the main option.
No. It maps and cleans locally, and nothing leaves your home. Home Assistant integration is there if you want it.
Pick a task from the Requests for Contributions board, read the contributing guide and say hi on r/oomwoo or Discord. Code, CAD, electronics and testing are all welcome.
Thank you for asking! Money is not an issue, so I'm not looking for donations. The best help is spreading the word - tell a friend who would want one, share OOMWOO online, or star the repo. You can also subscribe below to hear when kits are available, or pick up a task on the RFC board.
Code is Apache-2.0. Hardware design files will use an open hardware license, still to be chosen.